Max PfingsthornIntelligence for the physical world.

I lead teams that bring AI and robotics into industrial use.

Currently Head of Applied AI at WasteAnt in Bremen. I lead a team of seven working across 18 industrial installations. Previously Bosch Research and OFFIS.

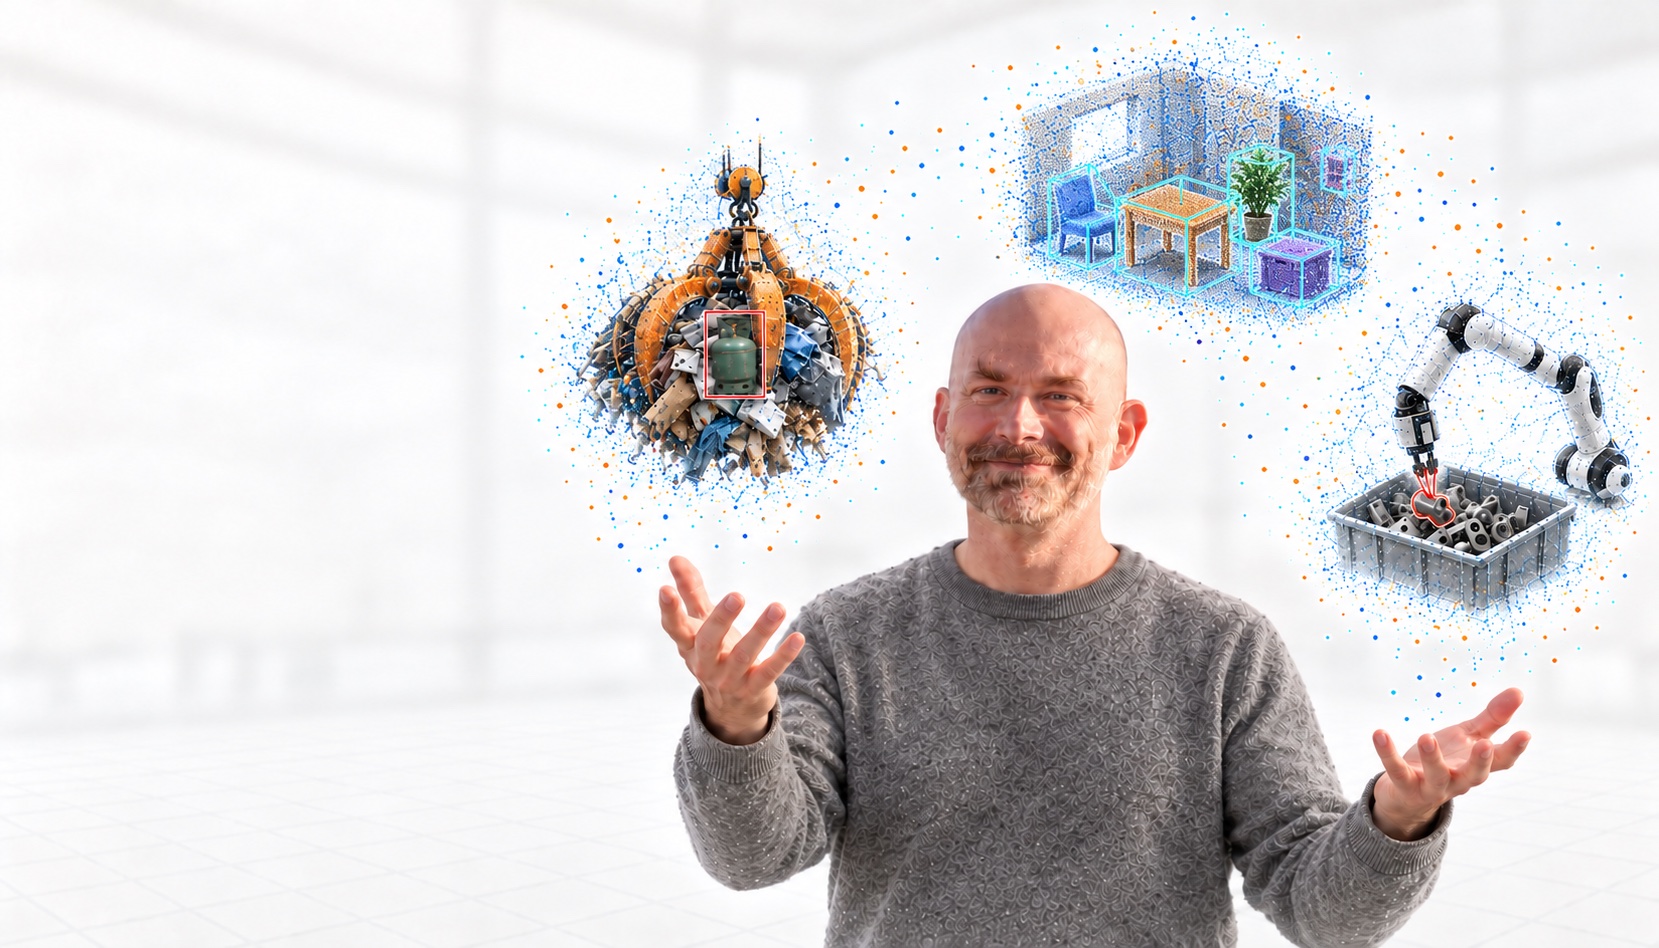
Generated illustration of Max Pfingsthorn juggling three point-cloud scenes: a gas cylinder among mixed waste in a crane grab, spatial mapping and scene understanding, and robot-arm bin picking
Perception concepts, illustrated.

Selected work

From perception in the field to systems a team can run.

WasteAnt

Applied AI & 3D mapping

Perception in industrial operation

I lead edge AI perception and 3D bunker mapping for industrial waste handling. My hands-on work includes crane localization, LiDAR–camera calibration and field validation.

I traced the detection-to-alarm pipeline and reduced observed peak latency from roughly 15 minutes to under one minute.

WasteAnt

Model deployment

Models that data scientists can operate

I established a shared forecasting runtime with MLflow deployment and continuous comparison of candidate models alongside the live model.

Data scientists can now promote models to production without DevOps support.

Bosch Research

Robotic manipulation

3D perception for industrial bin picking

For Smart Item Picking, I integrated Grounding DINO and SAM with RGB-D data to segment objects in 3D. That perception fed grasp-surface estimation and supported scene-graph development.

About Smart Item Picking at Bosch

How I lead

I build teams and the systems that let specialists do their best work.

That means clear ownership, reliable delivery paths, and time to focus. At WasteAnt, I shape the technical roadmap with company leadership and build the workflows that let specialists independently develop, deploy, and monitor models.

At OFFIS, I built and led the Smart Human-Robot Collaboration group, with responsibility for hiring, budgets and professional development.

My technical depth helps me challenge an approach, unblock a difficult problem, and hand ownership back to the team.

I clarify customer needs, weigh delivery cost and urgency, and look for solutions that strengthen the shared product.

Research &
community

My PhD at Jacobs University Bremen focused on graph-based SLAM under ambiguous measurements. My research continues in 3D perception and scene reconstruction.

I serve on the jury for the Georges Giralt PhD Award, recognising doctoral research in European robotics.

All publications on Google Scholar

Consulting

I help teams integrate and troubleshoot ROS/ROS 2 systems, assess perception pipelines, and move AI prototypes into maintainable production systems.

My experience spans more than a decade of ROS-based robotics, from research demonstrators to industrial edge deployments. I led our team in DLR’s SpaceBot Cup.

My ROS 1 and ROS 2 work includes SLAM pipelines, integration of the ROS 1 navigation stack, use of ros_control, MoveIt, Behavior Trees, and MCAP data capture for field debugging and validation. At WasteAnt, I also build data loops that consume ROS data and deploy updated models into containerized ROS nodes.

Let's compare notes.

Always happy to have conversations on AI in waste-to-energy, perception, MLOps, robotics, leadership, and mentoring. That also includes technical leadership roles, selected consulting engagements, and research collaborations.

max@pfingsthorn.de